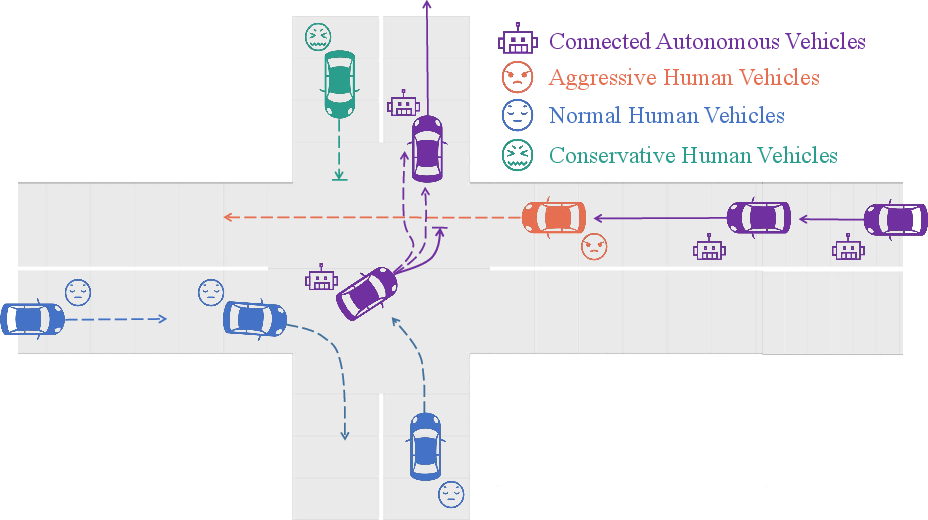
- The paper introduces a novel cooperative decision-making framework using a Normalized Cooperative Level-k game to allocate right-of-way effectively at unsignalized intersections.
- The paper leverages real-world traffic data and inverse reinforcement learning to simulate heterogeneous human-driven vehicle behaviors, enhancing safety and efficiency.
- The paper validates its framework through extensive simulations that demonstrate improved average speeds, reduced delays, and higher safety metrics compared to traditional methods.
"Cooperative Driving of Connected Autonomous Vehicles in Heterogeneous Mixed Traffic: A Game Theoretic Approach" (2305.03563)
Introduction
The paper investigates cooperative driving of Connected Autonomous Vehicles (CAVs) amidst heterogeneous mixed traffic characterized by high-density unsignalized intersections. These intersections pose challenges in efficiency and safety due to the intricate interactions between CAVs and Human-driven Vehicles (HVs). The authors propose a novel cooperative decision-making framework leveraging game theory to resolve conflicts effectively.
Framework for Cooperative Driving
The proposed framework synthesizes the interaction dynamics between CAVs and HVs using a Normalized Cooperative game combined with a Level-k game (NCL game). Central to this approach is effectively allocating Right of Way (ROW) to maximize system efficiency and safety.
Reproduction of Heterogeneous HV Decisions
A fundamental aspect of this study involves simulating HV decisions in mixed traffic using real-world interaction data. The paper employs classification techniques to categorize drivers into distinct behavior profiles—aggressive, normal, and conservative—and mathematically models these using non-cooperative game theory.
- Data Collection: Interaction data was sourced from a real-world intersection study, leveraging Post Encroachment Time (PET) as a key metric to understand HV behavior.
- Behavior Modeling: Inverse Reinforcement Learning (IRL) was used to calibrate the decision-making preferences, optimizing reward functions that represent efficiency, comfort, and safety priorities.
Algorithmic Implementation
The authors detail a multi-layer hierarchical approach to CAV decision-making and trajectory planning, integrating Level-k game logic into trajectory generation via Lattice planner.
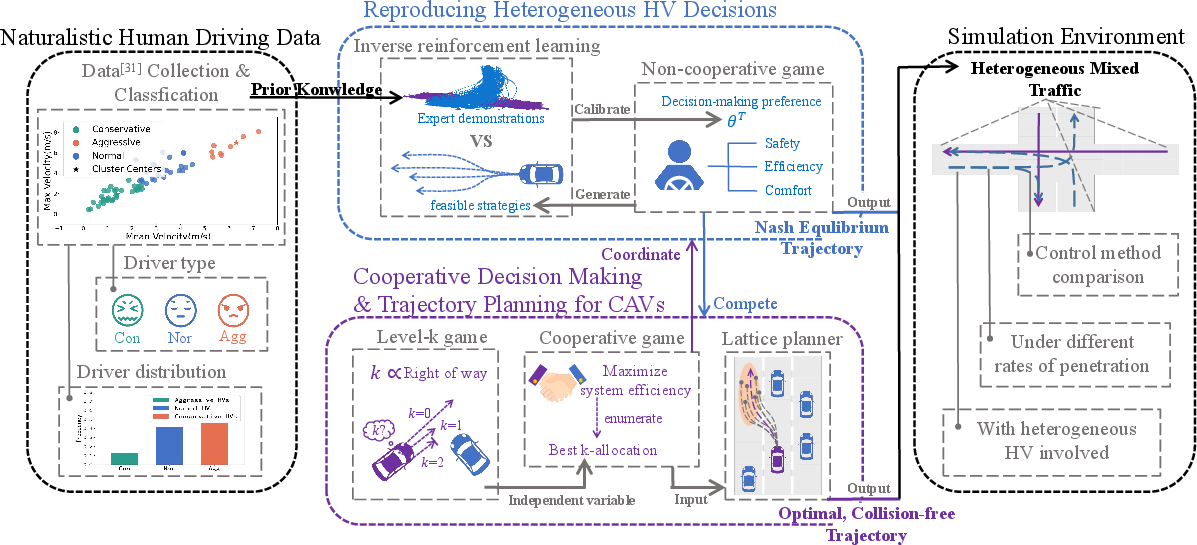
Figure 2: Cooperative driving framework in mixed traffic.
- Lattice Planner: Utilizes transformed coordinates and sampling strategies to generate collision-free trajectories. The optimization process maximizes the reward functions calibrated earlier through IRL, ensuring CAVs interact effectively with HVs.
Simulation Results and Validation
Extensive simulations validate the framework's effectiveness under varied conditions including different CAV penetration rates (ROP) and heterogeneous driver compositions. Key performance metrics include average travel speed, total delay, and PET, demonstrating significant efficiency and safety improvements.
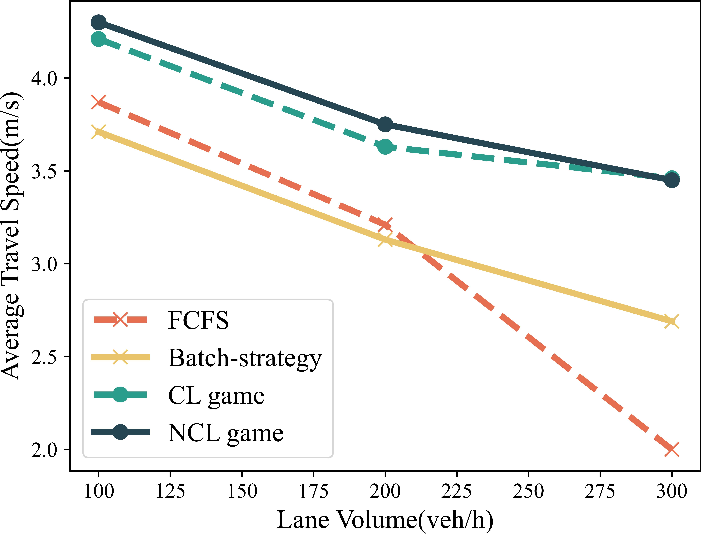
Figure 3: Average travel speed comparison of control method under different lane volume.
- Comparison with Traditional Methods: The NCL game outperformed reservation-based control methods such as FCFS and Batch-strategy, especially in high-density scenarios, showing resilience and improved throughput and delay metrics.
- Safety Analysis: PET analysis revealed a higher concentration and elevated minimum PET in scenarios with increased CAV penetration, indicating better conflict resolution and overall traffic safety.
Conclusion
The game-theoretic framework proposed in this paper offers a robust approach for managing CAVs in complex, unsignalized intersection environments. It advances current methodologies by introducing cooperative elements that account for heterogeneous traffic dynamics. Future work could explore scaling this approach to larger, more varied traffic networks and integrating real-time data from infrastructure sensors for dynamic adaptability.